Hi there, I’m

Jinglin Cao. 曹景琳

Robot intelligence, beyond the script.

I’m an M.S. student at UC San Diego and a Research Intern at Aether AI. Previously, I worked with Prof. Michael Yip at ARCLab on robot learning (Jan–May 2026).

I study open-ended and long-horizon robot autonomy through causal reasoning, behavioral memory, and world models. My work spans CRIS-0’s agent planning and execution and CAMP’s memory for manipulation—toward robots that discover tasks from context, compose skills, and recover from failure.

I earned my bachelor’s at Tongji University and previously worked at Jingwei Hirain on dynamic perception. I welcome collaborations—get in touch.

Looking for full-time research / robotics roles in 2027

San Diego, California

JC / 2026
Portrait of Jinglin Cao
UC San Diego · Aether AI
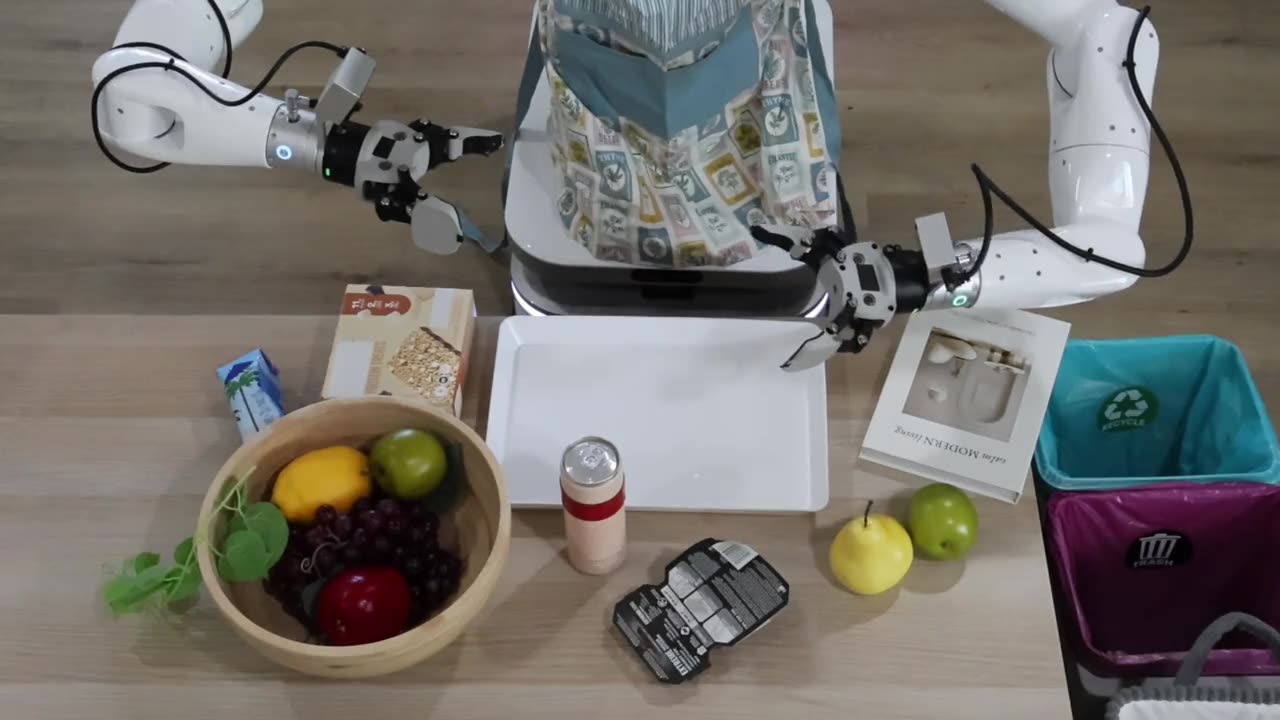
Public CRIS-0 household robot demonstrationCRIS-0 / IN THE REAL WORLD From context to action.
01CRIS-0Causal agents · AgiBot G1 02CAMPBehavioral memory · CoRL Workshop / TRA 03Video2WorldVideo-to-simulation · 222 instances

SELECTED WORK

Selected research

From robot behavior to the benchmarks that measure it.

Official CRIS-0 film cover: Aether AI and a household robot demonstration 01 / SYSTEMS Real objects. Changing context.CRIS-0 · AETHER AI

CRIS-0

Co-first authorReleased Oct 2026

A Causal Robotic Intelligence System

A causal agent and world model working together for long-horizon robot autonomy. I owned the agent-side planner, executor, unified tool interface, and execution policies, integrating the Causal World Action Model policy on AgiBot G1.

Causal task state · Skill orchestration · Recovery

My contribution

Built explicit causal task states and verifiable stage transitions for retry, rollback, and replanning. Constructed stages, verification criteria, and tools from a small set of demonstrations, coordinating rule-based motion, learned policies, navigation, and verifiers. The public demonstrations include long-horizon tidying, tablecloth replacement, and skill transfer to new objects.

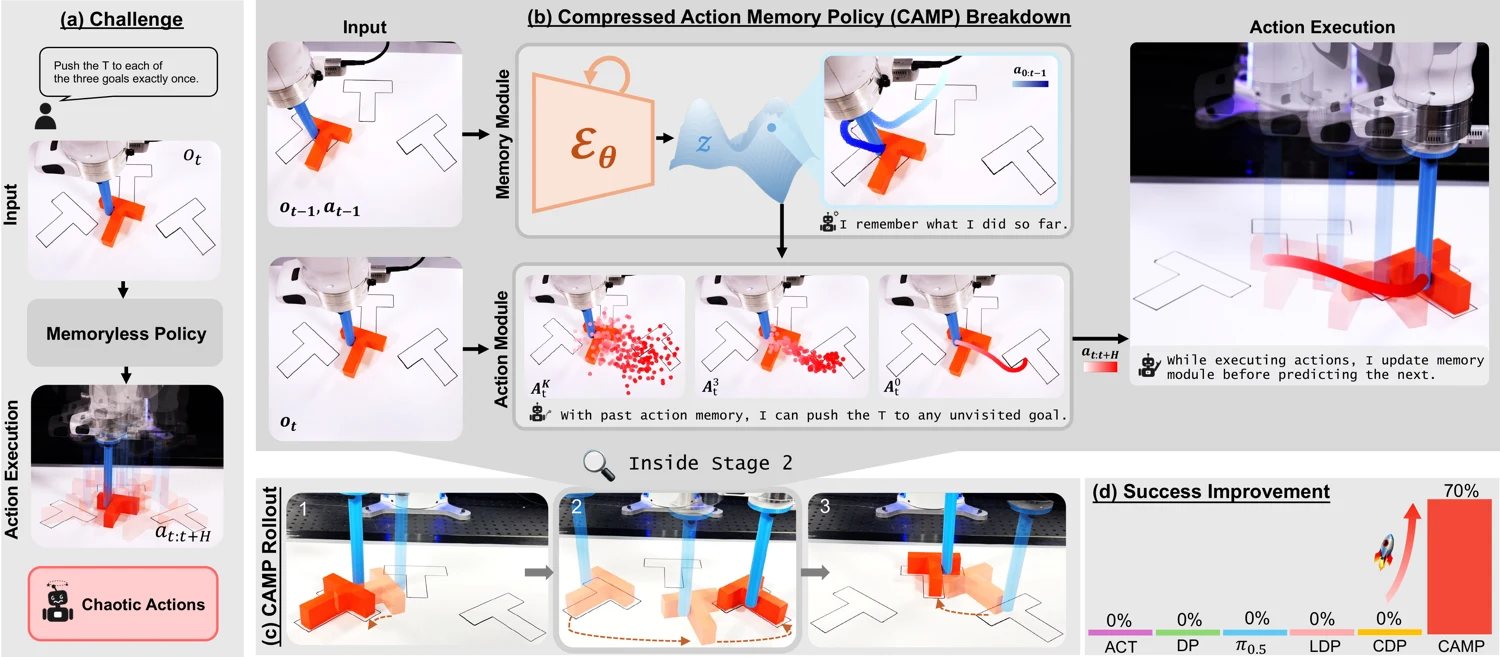
CAMP main figure: behavioral memory, action execution, and real-robot demonstrations 02 / ROBOT LEARNING The next action has a history.CAMP · FRANKA PANDA

CAMP

Co-second author · UC San Diego ARCLabSubmitted to CoRL Workshop & TRA

Behavioral memory for partially observable manipulation

Learning from what a robot has already done. CAMP uses action-history reconstruction to learn compact behavioral memory for Diffusion Policy. My contributions focus on Memory-T-Bench / Memory-Manip-Bench demonstration and evaluation infrastructure, plus baseline experiments.

64.3% mean success across seven 3D tasks +23.4 pp

Paper details

Remember what you did?: Learning Behavioral Memories for Partially Observable Object Manipulation

Co-second author, advised by Prof. Michael Yip. Submitted to CoRL Workshop and TRA. Built Memory-T-Bench / Memory-Manip-Bench demonstration and evaluation infrastructure and ran ACT, Diffusion Policy, π0.5, and MemoryVLA baselines. Paper results include 64.3% mean success across seven 3D tasks (+23.4 percentage points over the best baseline). In four Franka Panda tasks, three reached 7/10 versus 0/10 for all baselines; Probe-Insert reached 11/15.

CAMP architecture, behavioral memory, and manipulation experiments
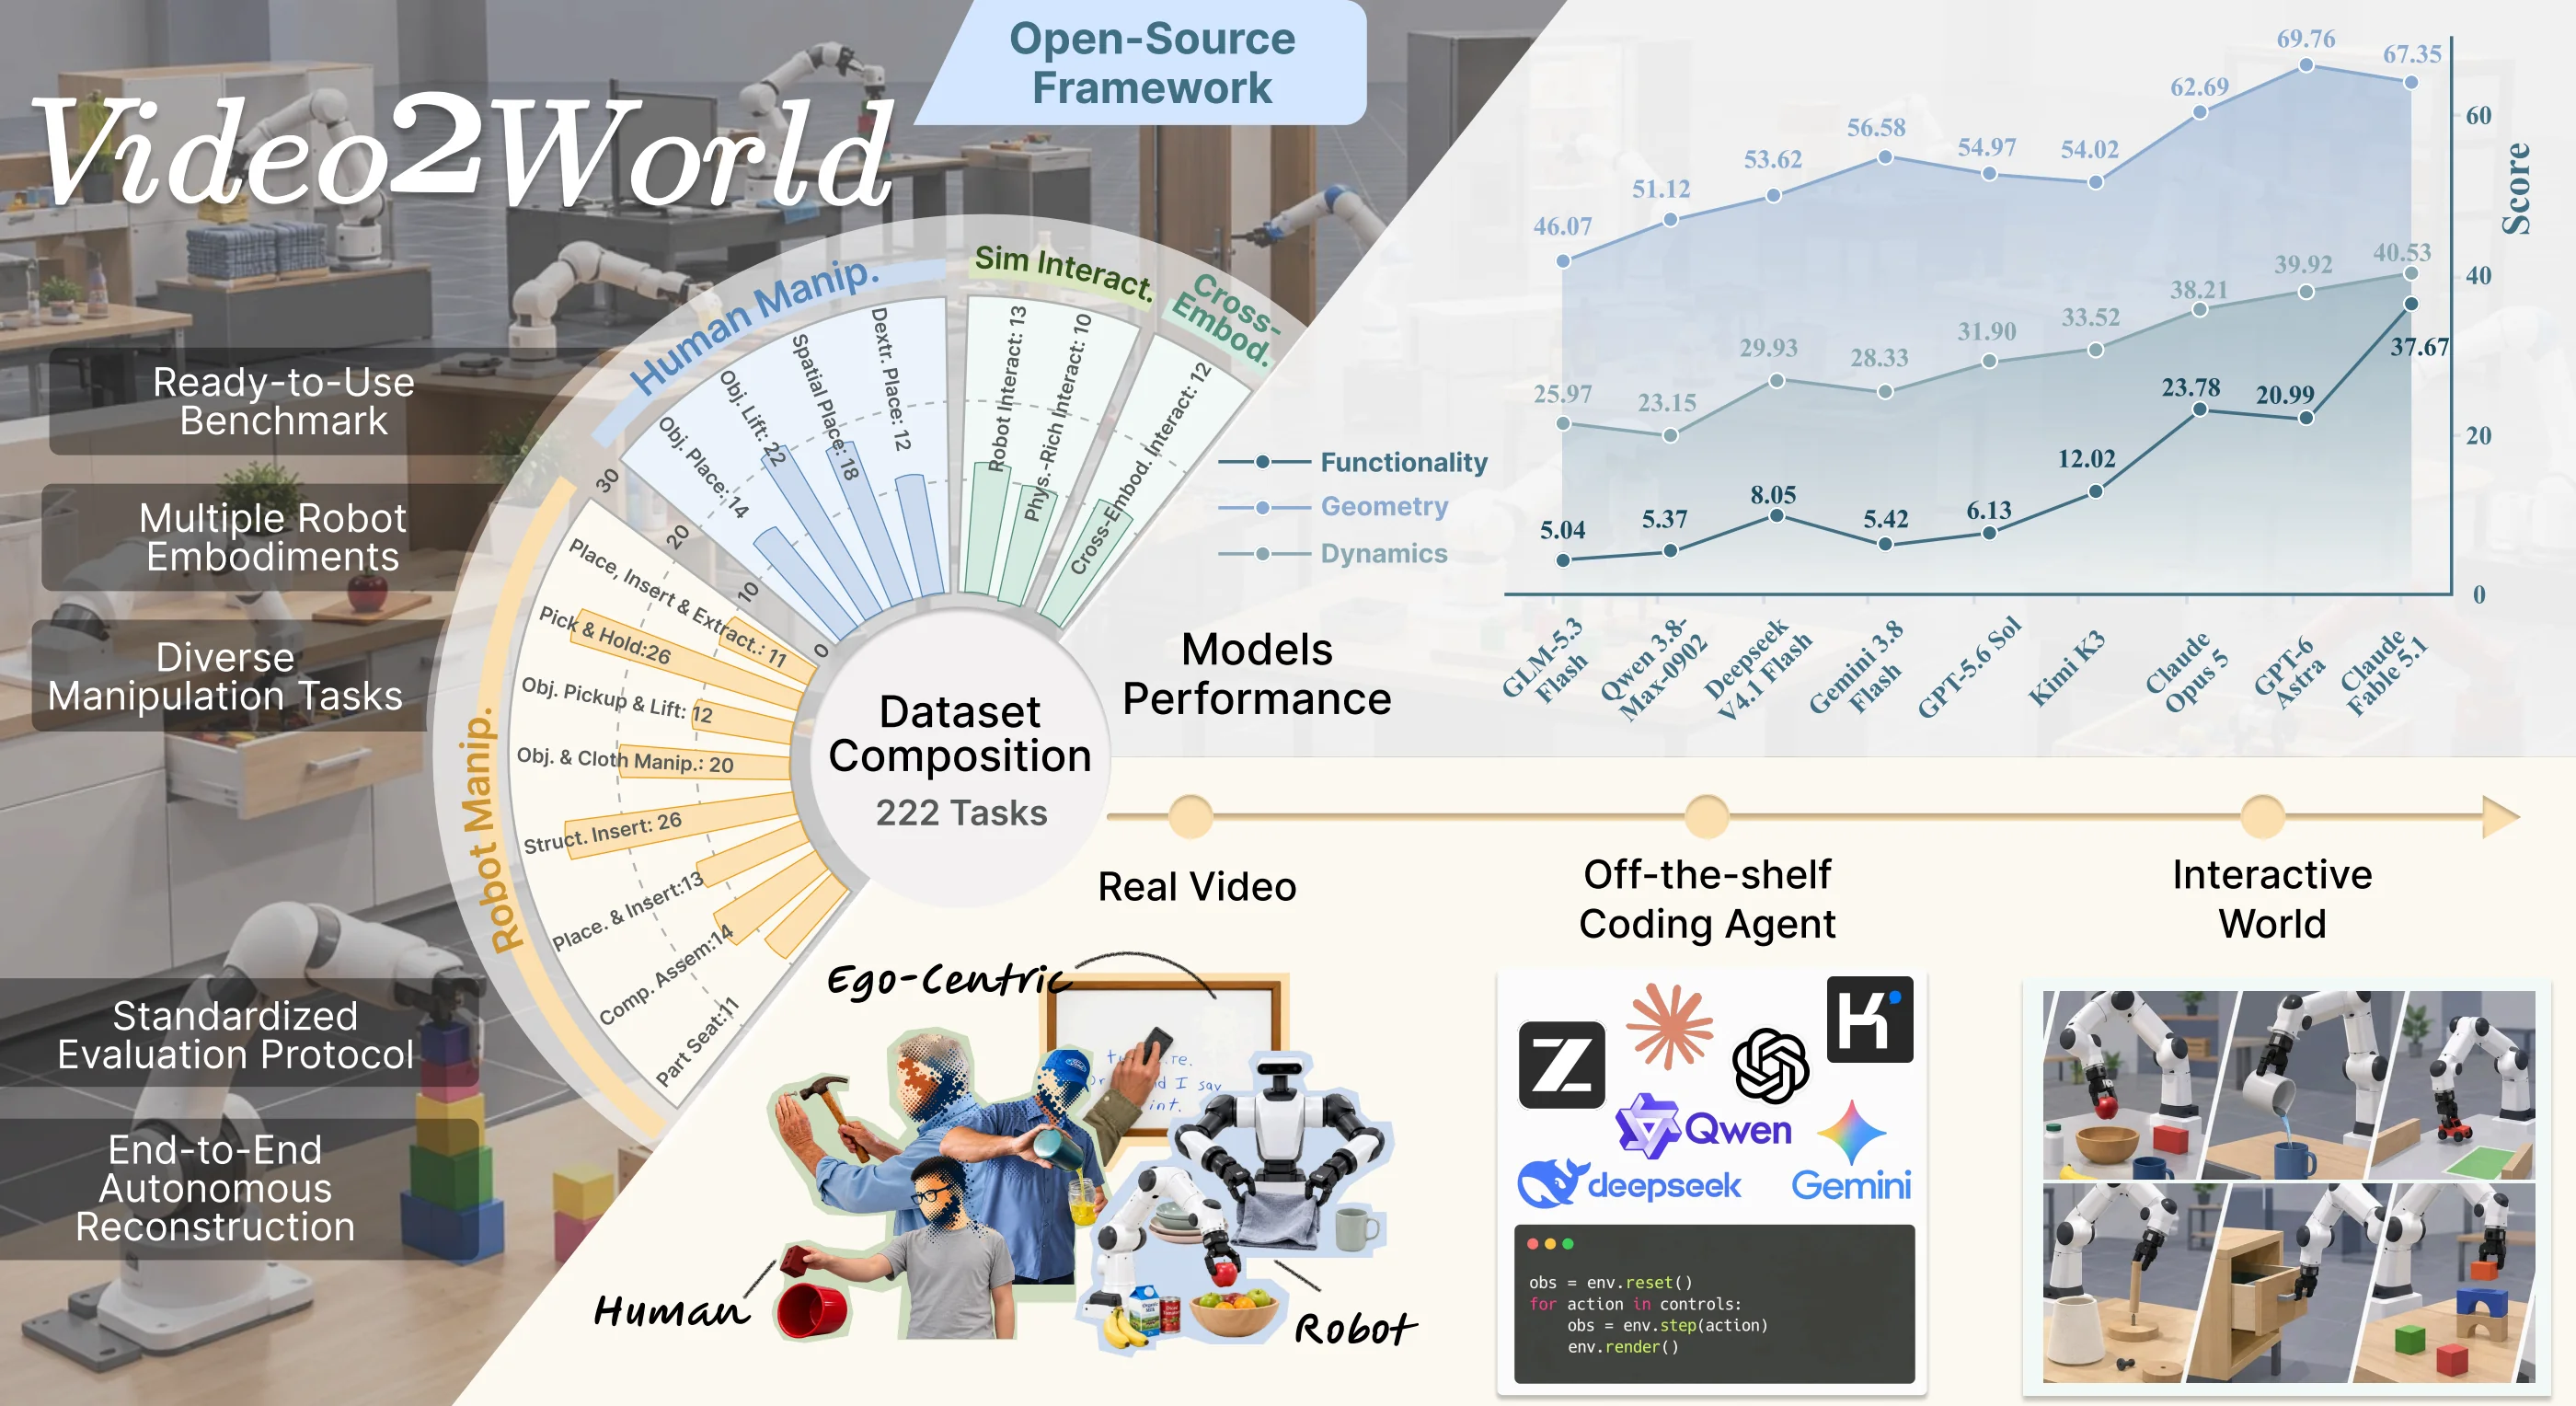
Video2World overview: embodied videos, coding agents, interactive simulations, and benchmark evaluation 03 / WORLD MODELING

Video2World

Author · Aether AIarXiv · Oct 2026

Benchmarking coding agents for interactive world modeling from embodied videos

A benchmark for coding agents that turn robot and human demonstration videos into executable simulations. Agents reconstruct the scene and robot behavior, then refine them through execution feedback. Evaluation separates geometric fidelity, dynamic fidelity, and functional correctness.

222reconstruction instances189source videos39task families9coding agents

BACKGROUND

Experience & education

Tongji → UC San Diego → Aether AI

Experience

Apr 2026 — Present

Aether AI

Research Intern · Embodied AI & Robot Learning

Agent planning, execution, tool interfaces, and Causal World Action Model policy integration for CRIS-0; robot-agent evaluation and Video2World.

Jan 2026 — May 2026

UC San Diego · ARCLab

Student Researcher · Robot Learning

Advanced Robotics and Controls Laboratory, advised by Prof. Michael Yip. Co-second author of CAMP; built Memory-T-Bench / Memory-Manip-Bench demonstration and evaluation infrastructure and ran ACT, Diffusion Policy, π0.5, and MemoryVLA baselines.

Jul 2025 — Sep 2025

Jingwei Hirain Technologies

Dynamic Perception Algorithm Intern

Camera / LiDAR / radar auto-labeling, CLIP-based data filtering, and BEVFormer perception.

Education

Sep 2025 — Dec 2026 (expected)

University of California, San Diego

M.S. · Machine Learning & Data Science

Robot learning research at ARCLab with Prof. Michael Yip (Jan–May 2026).

Sep 2021 — Jul 2025

Tongji University

B.Eng.

TOOLS I WORK WITH

PyTorch · ROS / ROS 2 · MuJoCo · Isaac / Genie Sim · robosuite · LeRobot · Python · C++

LET’S CONNECT

Contact & CV

I’m interested in research and engineering roles in robot learning, embodied agents, and evaluation starting in 2027.

williamcao1943@gmail.com
CURRICULUM VITAEEnglish CV中文简历Available on request